Designed for movement.
An articulated quadruped architecture with aluminum components and a defined kinematic model, connecting physical design to control.
 chinbiROBOTICS
Intelligent movement starts with thoughtful engineering. We’re building a quadruped platform that connects mechanical design with learned control.
Meet the platform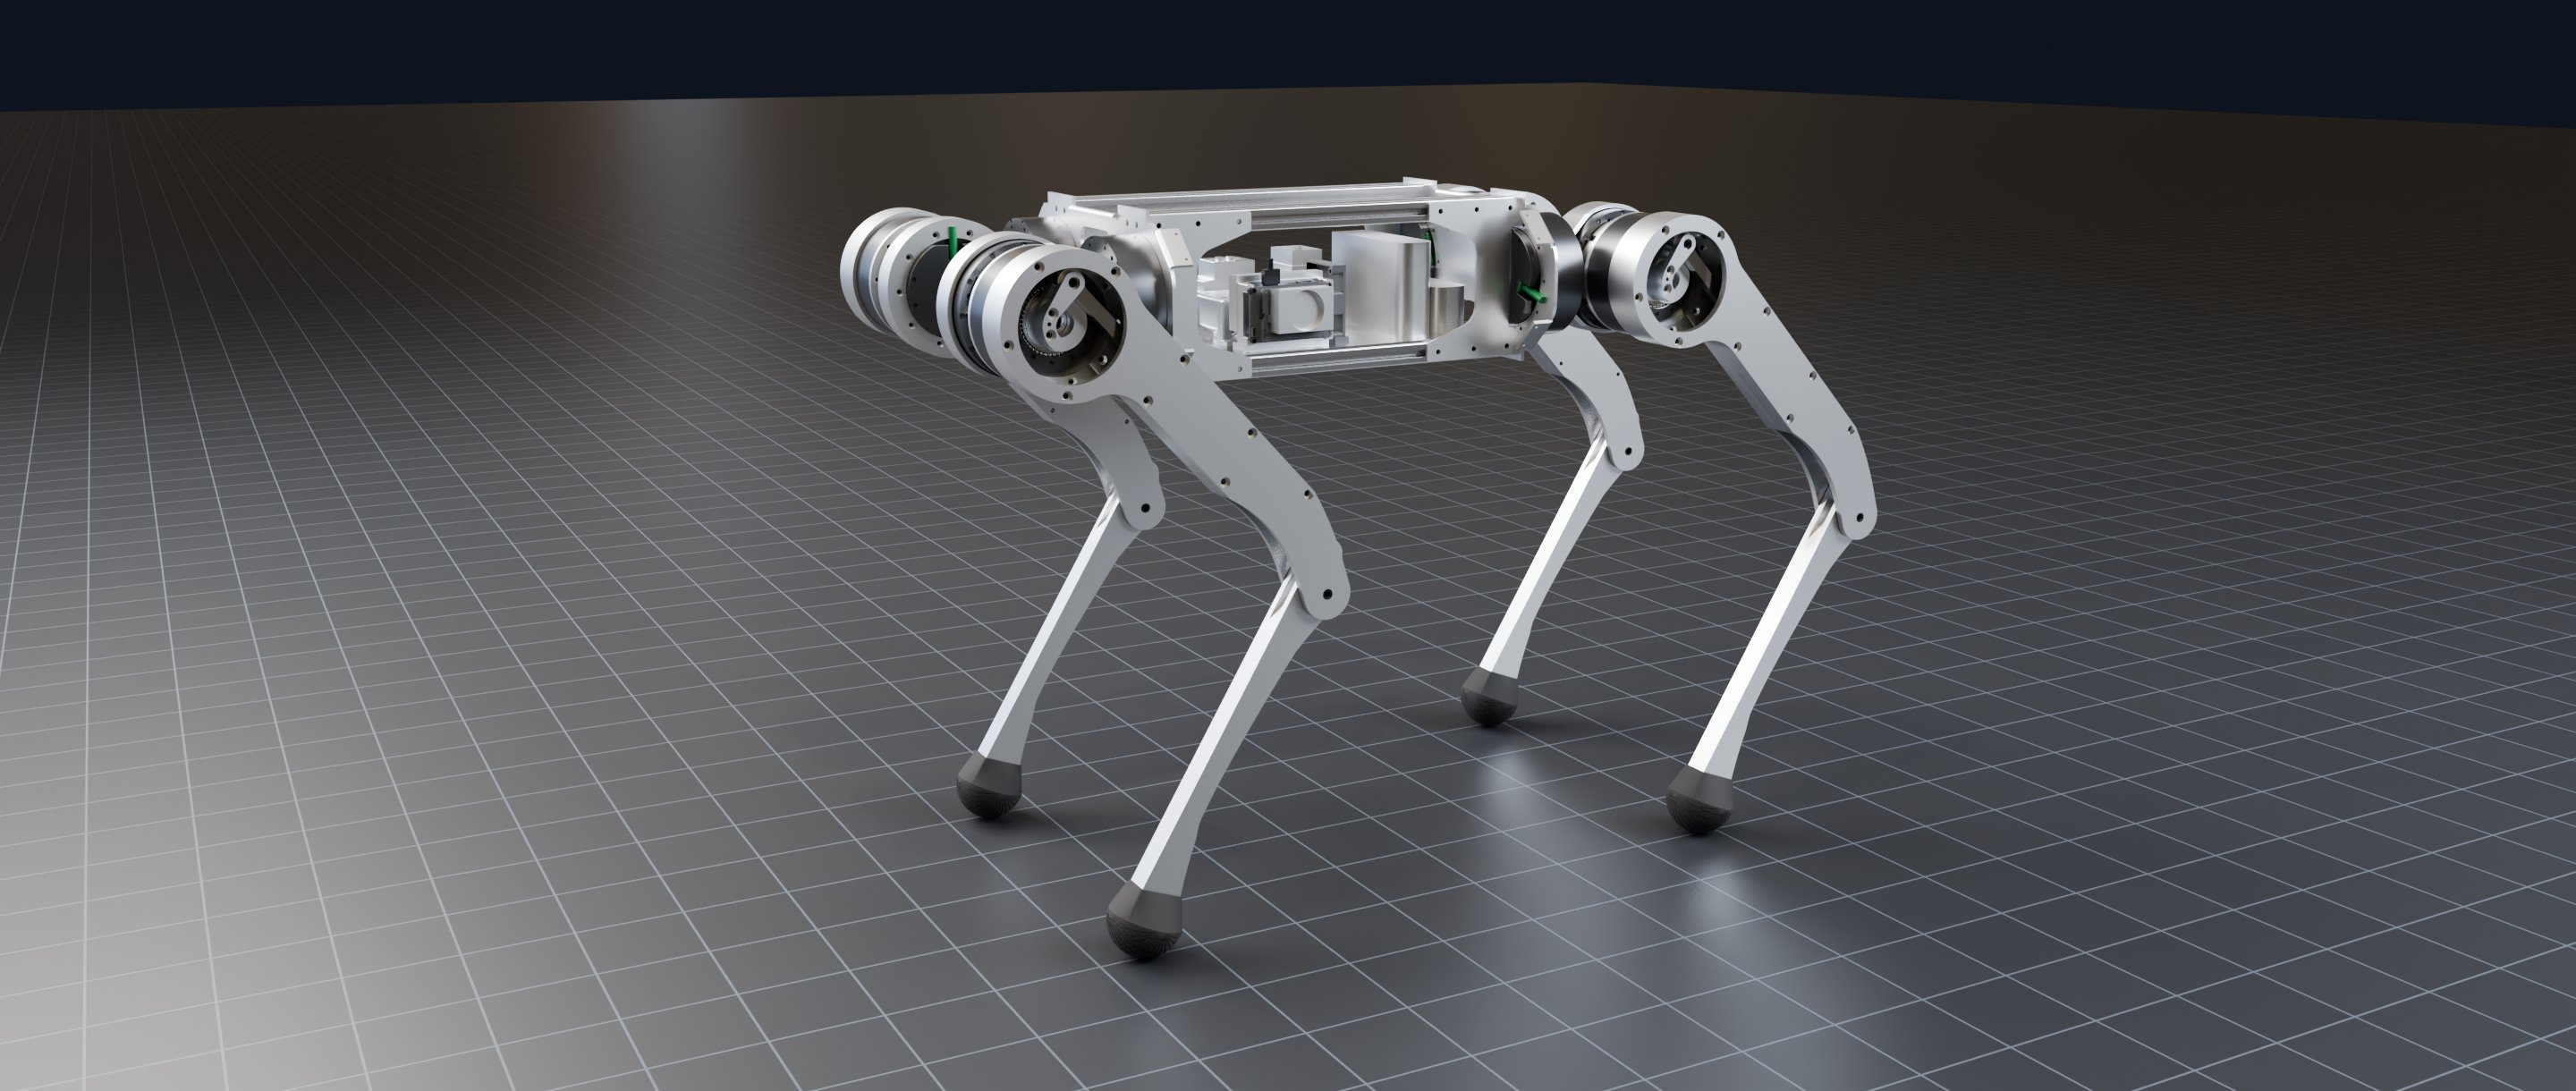
A research platform for exploring how robots move, balance, and interact with the physical world. Developed from the joint up.
Specifications of the V1 robot model.
A full-size four-legged robot designed, machined, and programmed in Vietnam — with direct local support from the team that built it.
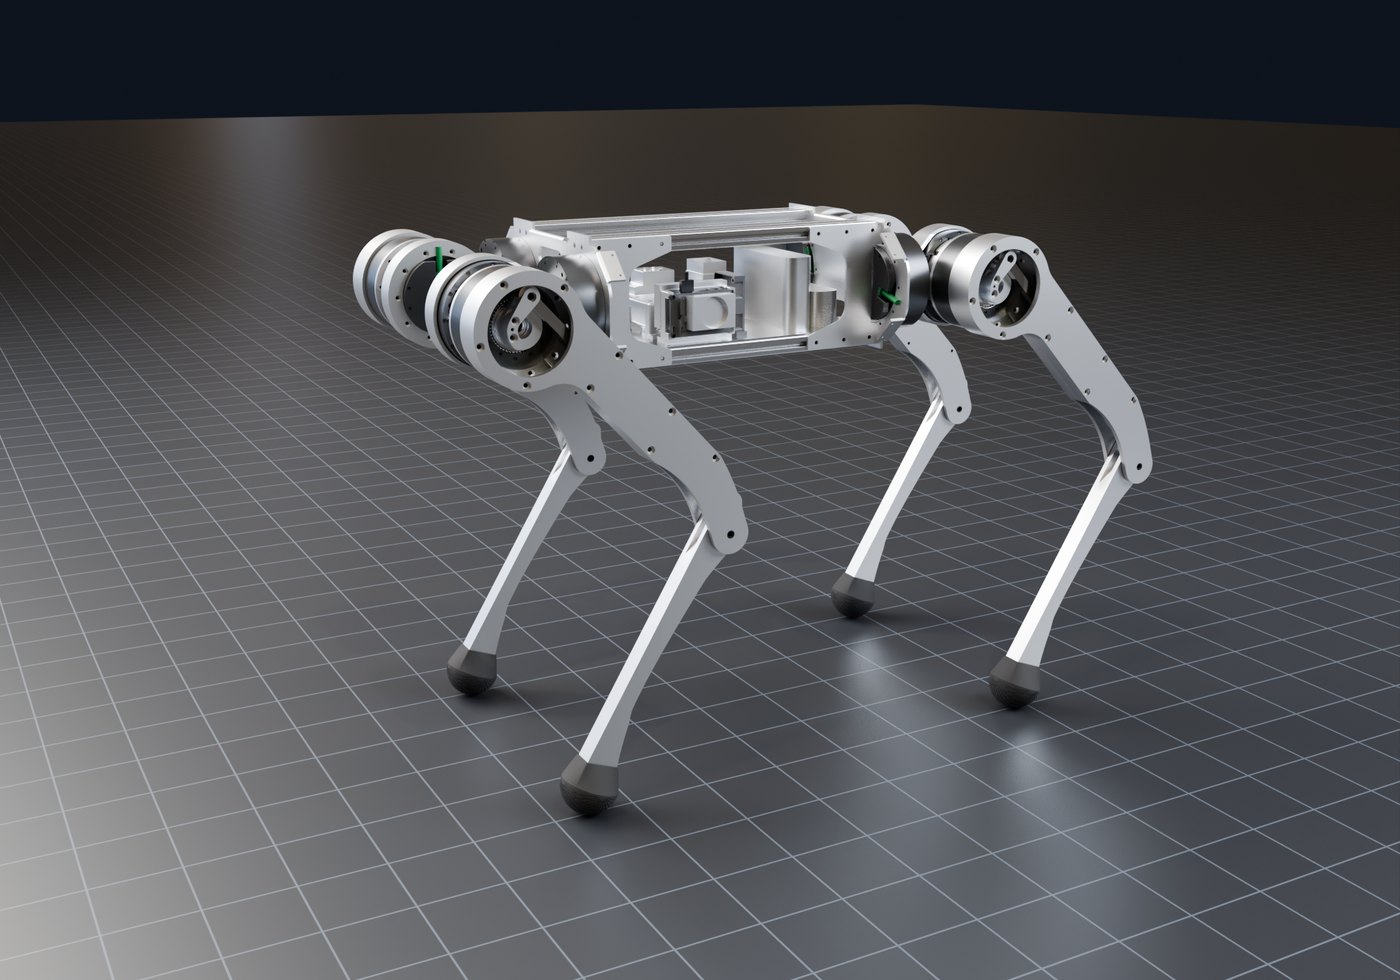
One complete robot, about 30 kg — everything below is included.
Physics simulation (MuJoCo) of Chinbi V2 with its trained control policies. Videos play automatically as you scroll.
| Weight | ~30 kg with battery |
| Actuated joints | 12 (3 per leg: abduction, hip, knee) |
| Actuators | QDD, 9:1 · 120 Nm torque · 14-bit absolute encoder |
| Payload | Up to 12 kg |
| Onboard computer | NVIDIA Jetson Orin Nano 8 GB · neural-network control policy |
| Sensors | Intel RealSense D435i depth camera · BMI088 IMU (400 Hz) · joint encoders |
| Communication | CAN bus to actuators · Wi-Fi · Bluetooth gamepad |
| Battery | 12S LiPo, 44.4 V, 10 Ah (444 Wh) · swappable |
| Run time | ~45–85 min depending on activity |
| Motions | Walk, trot, turn, stairs, sit/stand, jump, spin, side flip, fall recovery |
Images and video are renders of the actual CAD model. Contact us for delivery time.
Hardware and software evolve together. Our development workflow brings design, simulation, and control into the same loop.
An articulated quadruped architecture with aluminum components and a defined kinematic model, connecting physical design to control.
Reinforcement learning trains locomotion policies in simulation, which are then deployed on the robot.
Robot descriptions and simulation environments let us examine joint behavior, improve control, and iterate on the platform.
We believe legged robots can extend what machines can do beyond structured environments.
Chinbi Robotics is at the beginning of that journey. Our focus today is the foundation: a capable mechanical platform, reliable control, and a disciplined path from simulation to the physical world.
Follow the engineering journeyWe build the platform step by step, from actuators to learned control.
All 12 actuators wired on a CAN bus, with stable low-level control confirmed on the physical robot.
A flat-ground walking policy trained in Isaac Lab — PPO, ~3,000 iterations, ~43 minutes on a single RTX 3060 — reaching a 99.2% survival rate.
Running the trained policies on the physical robot: walking, stairs, and dynamic moves.
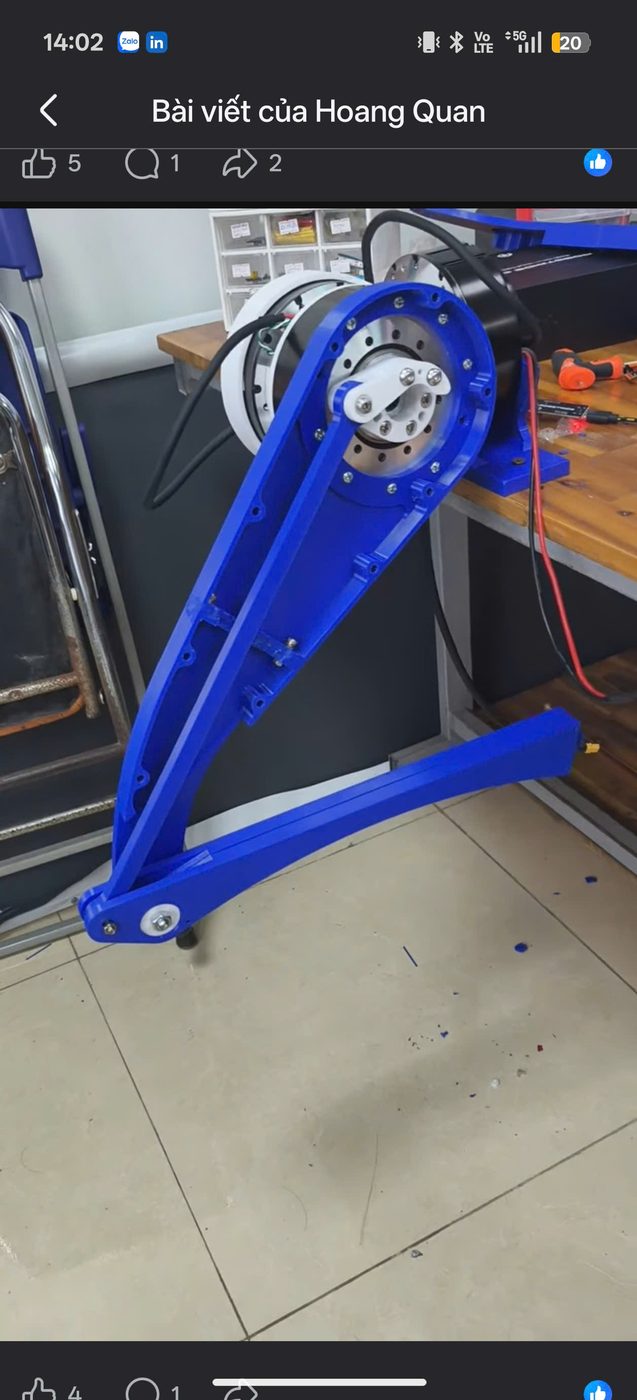
In-house design across mechanics, control, and locomotion — with a clear roadmap to localize the one component we still source externally.
| Component | Status | Note |
|---|---|---|
| Mechanical design (frame, joints, legs) | In-house | Design, simulation, and in-house machining / 3D printing |
| Real-time control & firmware | In-house | STM32H7, CAN bus scheduling, custom-written drivers |
| Locomotion algorithms (RL) | In-house | Isaac Lab, custom reward design & training curriculum |
| Systems & sensor integration | In-house | Hardware architecture, power system, sensor suite |
| QDD actuators & power electronics | Phase 1: sourced | Phase 2: in-house motor & driver development |
Phase 1: source actuators externally. Phase 2, once resourced: develop motors and drive electronics in-house — targeting ≥80% localization.
Electronics and machining partners near Thái Nguyên form a fairly complete local ecosystem, shortening the design-to-prototype loop.
PCT patent WO/2026/109238 (embedded vapour-chamber cooling); a Chinbi trademark application is filed with Vietnam’s IP Office.
Legged robots are becoming real operating tools. Vietnam imports nearly 100% of them today.
Resolution 57-NQ/TW makes science, technology, and digital transformation a national priority, with strong incentives for deep-tech startups; a “state–university–enterprise” mechanism is designed to push research to market.
Most domestic “robotics companies” import and distribute robots from China. Very few own the full stack — mechanical, electronics, control, AI — and manufacture locally.
We win on local price, on-the-ground support, and owning the technology — not on raw spec sheets.
| Criteria | Chinbi | Unitree A2 | Boston Dynamics Spot |
|---|---|---|---|
| Price (comparable class) | 200M VND (~US$8K) | ~1.3B VND (~US$52K) | ~1.7B VND (~US$68K) |
| Event rental service | ~15–25M VND/event, with technician | No such service | No such service |
| Local support & customization | Direct, full-stack | Through a distributor | Very limited |
| Firmware / control ownership | Yes — custom-written | No (closed) | No (closed) |
| Localization / dual-use potential | Roadmap to ≥80% localization | None | None (export-restricted) |
Rental rate ~15–25M VND per event (single day); multi-day packages ~12–18M VND/day, with an on-site technician.
A talented, experienced founder
University classmates now pursuing PhDs at Harvard and ETH Zürich; research friends across AI PhD programs in the UK, US, France, and Switzerland — a channel to international talent, technology, and partners.
Technical standards, documentation, and product positioning are export-oriented from the start, built on the founder’s personal network in these markets.
The team around the founder
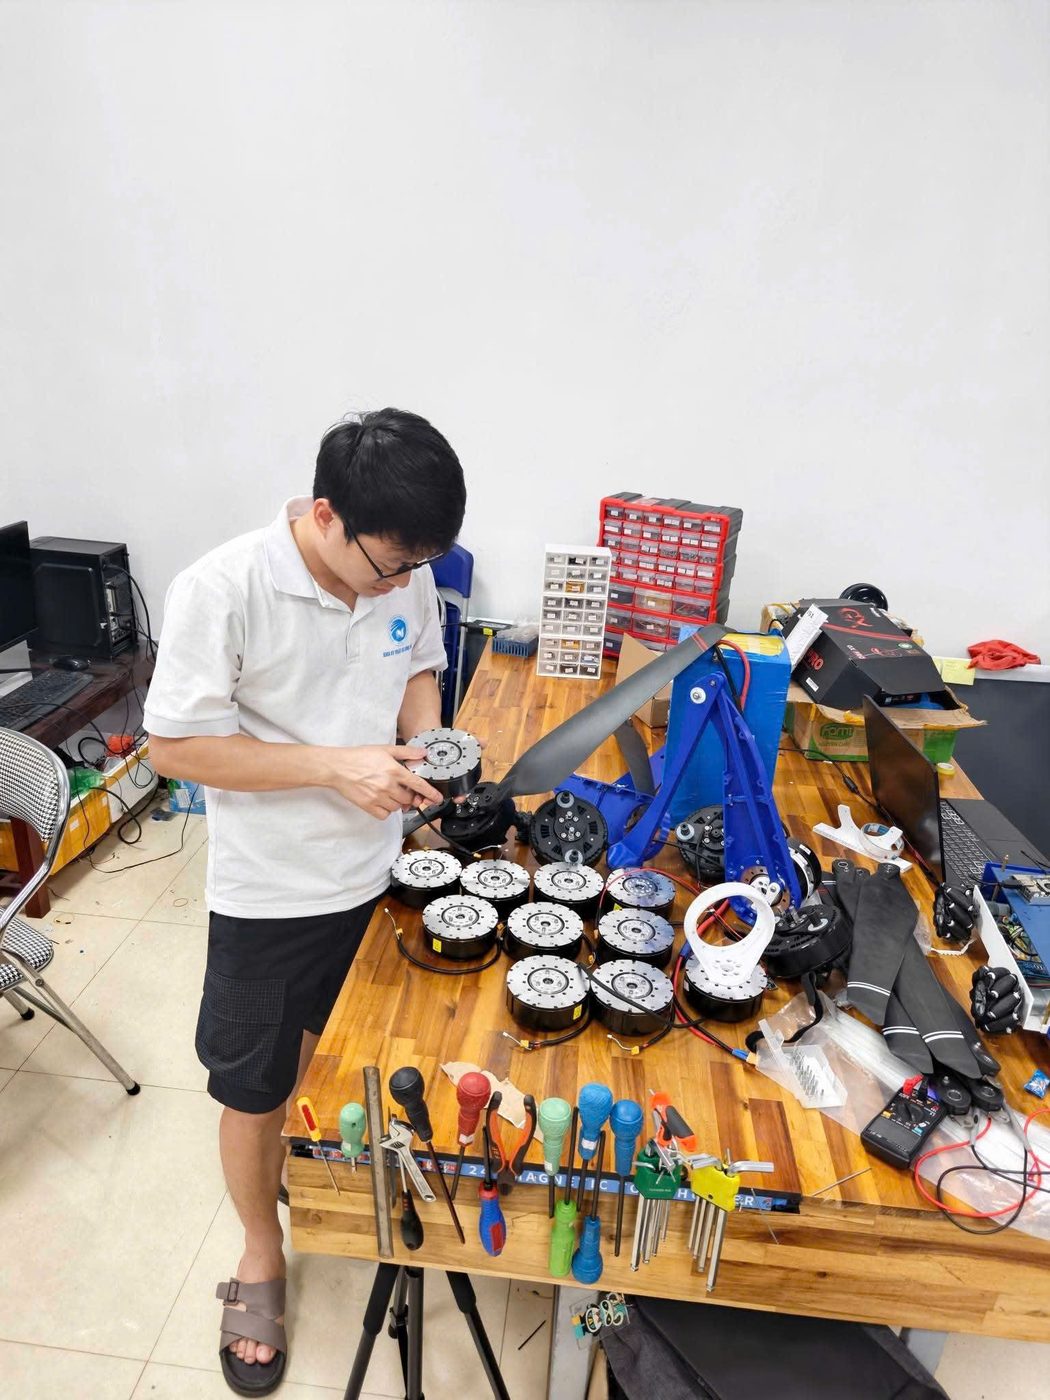
Young mechanical, electronics, and controls engineers — continuously supplemented from the Smart Mechatronics research group at ICTU.
First-time CEO — but with a track record managing technical delivery in international industrial R&D.
Access to international AI/robotics expertise through the founder’s network (Harvard, ETH Zürich, UK, US, Switzerland).
A faculty position brings free lab space & power, direct connections into the education ecosystem, and shared lab infrastructure.
Contact us for orders, demos, event rentals, and partnerships.